AI-powered Firefighting UGV Rover
This project presents the development of a fire-fighting robot that integrates fire detection and suppression mechanisms. Built on the UGV Rover platform, the system is designed to operate without human intervention in hazardous environments like industrial zones and disaster recovery operations.
Highlights
- AI Vision System: Developed a real-time fire detection module using the YOLOv8 deep learning model integrated with OpenCV, processing live video feeds with high accuracy.
- Detection & Actuation: Once fire is identified, the system automatically triggers a shooting mechanism via WebSocket communication for fast, asynchronous response.
- Hardware Integration: Utilizes a Raspberry Pi 5 for high-level vision processing and task execution, while an ESP32 microcontroller handles motor control and wireless communication.
- Suppression Mechanism: Equipped with a 3D-modeled Orbeez gun repurposed for fire suppression, controlled through a relay-based actuation system.
- Custom Engineering: Designed and 3D-printed a detachable mounting system and specialized tubes to ensure stable component integration and reliable operation during motion.
System Architecture
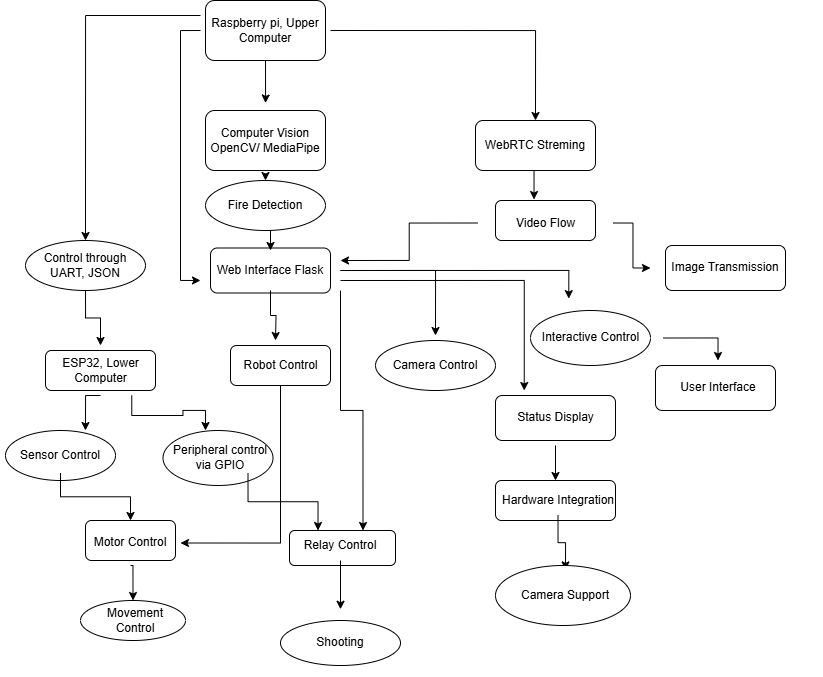
Diagram: Interaction between Raspberry Pi 5, ESP32, and YOLOv8 Vision Model.
Tools & Technologies
Hardware: Raspberry Pi 5, ESP32, UGV Rover Platform, Camera Module, Relay, Orbeez Gun.
Software: Python, YOLOv8, OpenCV, Flask Framework, WebRTC.
Protocols: WebSocket, UART (JSON-based messages), VNC Viewer.
CAD: 3D Modeling on Fusion 360 and Printing for custom hardware integration.